Orbital mechanics equips engineering students with the mathematical tools to model and predict spacecraft trajectories. The 4th edition PDF introduces foundational concepts‚ mathematical formulations‚ and practical examples‚ enabling readers to analyze motion in space environments. It improves design space.
Overview of the 4th Edition PDF
The 4th edition PDF of “Orbital Mechanics for Engineering Students” offers an updated‚ concise resource for modern aerospace curricula. It starts with a preface outlining a problem‑solving approach‚ emphasizing conceptual clarity and real‑world applications; The table of contents reorganizes contemporary mission design trends‚ highlighting interplanetary transfers‚ low‑Earth orbit operations‚ and spacecraft autonomy.
Each chapter is reorganized for clarity‚ with interactive examples in the introductions and expanded derivations in advanced topics. New sections cover atmospheric drag‚ solar radiation pressure‚ and third‑body perturbations. MATLAB/Simulink appendices provide ready‑to‑run scripts for orbit propagation‚ perturbation analysis‚ and mission optimization.
Illustrations have been updated with high‑resolution vector graphics‚ and the PDF includes hyperlinks to supplementary datasets and video demonstrations. A dedicated companion website hosts downloadable code‚ additional problem sets‚ and a forum for peer discussion. The edition also introduces a “Design Your Own Mission” module‚ guiding students through the entire mission planning cycle from launch window selection to trajectory correction maneuvers.Students can explore orbital debris mitigation and mission risk assessment in depth.
Overall‚ this edition serves as both a textbook and a practical toolkit‚ bridging theory and engineering practice for students preparing to design‚ analyze‚ and operate spacecraft in an increasingly complex orbital environment.
Core Physical Principles
Fundamental laws governing orbital motion—Newton’s law of universal gravitation‚ conservation of energy and angular momentum—form the backbone of trajectory analysis. These principles enable engineers to predict spacecraft behavior and design stable orbits. Precise modeling.
Newtonian Gravity and Keplerian Orbits
In the 4th edition PDF‚ the section on Newtonian gravity establishes the inverse‑square law as the foundation for celestial mechanics. The text explains how the gravitational force F = Gm₁m₂/r² governs the mutual attraction between two masses‚ leading to the derivation of orbital energy and angular momentum conservation. By integrating these principles‚ the book derives Kepler’s three laws‚ demonstrating that planetary motion follows conic sections—ellipses‚ parabolas‚ or hyperbolas—depending on the total mechanical energy. The discussion includes a step‑by‑step transformation from Newton’s second law to the standard orbital equation r(θ) = a(1 ⏤ e²)/(1 + e cosθ)‚ where a is the semi‑major axis and e the eccentricity. The PDF emphasizes the role of the central body’s mass in setting the orbital period via T = 2π√(a³/μ)‚ with μ = GM. Practical examples illustrate how to compute orbital elements from position and velocity vectors‚ and how perturbations such as atmospheric drag or solar radiation pressure modify the ideal Keplerian trajectory. The section concludes with a concise summary of how Newtonian gravity underpins all subsequent analytical and numerical methods presented in the book‚ providing engineering students with a rigorous yet accessible framework for designing and analyzing spacecraft orbits.
Orbital Elements and Their Interpretation
Orbital elements define a spacecraft’s trajectory. The 4th edition PDF details six classical parameters: semi‑major axis‚ eccentricity‚ inclination‚ RAAN‚ argument of periapsis‚ and true anomaly. These values uniquely specify an orbit for mission design.!
Classical Orbital Elements Explained
In the 4th edition PDF‚ classical orbital elements provide a concise description of a two‑body orbit. The six parameters—semi‑major axis (a)‚ eccentricity (e)‚ inclination (i)‚ right ascension of the ascending node (Ω)‚ argument of periapsis (ω)‚ and true anomaly (ν)—are defined in a heliocentric or geocentric frame. The semi‑major axis represents the size of the orbit and‚ via Kepler’s third law‚ relates directly to the orbital period. Eccentricity measures the deviation from circularity‚ ranging from 0° (perfect circle) to values approaching 1 for highly elongated ellipses. Inclination indicates the tilt of the orbital plane relative to the reference plane‚ with 0° being coplanar and 90° a polar orbit. The right ascension of the ascending node specifies the horizontal orientation of the orbital plane‚ measured from a fixed reference direction‚ typically the vernal equinox. The argument of periapsis locates the point of closest approach within the orbital plane‚ while the true anomaly gives the spacecraft’s instantaneous angular position from periapsis along the orbit. Together‚ these elements uniquely determine the spacecraft’s position and velocity vectors at any epoch‚ enabling trajectory propagation‚ mission planning‚ and perturbation analysis. The PDF illustrates each element with diagrams‚ equations‚ and example calculations‚ reinforcing the geometric intuition behind orbital mechanics; Students will also learn to compute orbital elements from observed data using squares fitting.
Two-Body Problem Solutions
The 4th edition PDF presents analytical solutions to the two‑body problem‚ deriving Kepler’s equation‚ vis‑viva relation‚ and orbital element evolution. It explains how to compute position and velocity vectors from time‚ enabling trajectory predictions. for design. and
Analytical Methods and Orbit Equations
In the 4th edition PDF‚ the analytical treatment of the two‑body problem is expanded to cover both classical and modern formulations. The section begins by revisiting the derivation of the vis‑viva equation‚ emphasizing the role of specific orbital energy and angular momentum. It then introduces Kepler’s equation in its canonical form‚ m = n(t – t₀) = E – e sin E‚ and discusses iterative solutions such as Newton–Raphson and Laguerre–Müller methods. The text proceeds to derive the timeofflight expression for elliptical‚ parabolic‚ and hyperbolic legs‚ providing explicit integrals that can be evaluated analytically or numerically. A detailed discussion of the Lambert problem follows‚ including the universal variable formulation and the use of Stumpff functions to handle all conic sections uniformly. The chapter also presents closed‑form expressions for the position and velocity vectors in Cartesian coordinates‚ derived from the orbital elements via rotation matrices that account for inclination‚ argument of periapsis‚ and right ascension of the ascending node. Finally‚ the section offers a concise summary of the relationships between energy‚ period‚ and semimajor axis‚ and illustrates how these relationships underpin mission design concepts such as Hohmann transfers and bieliptic maneuvers. The analytical tools are supplemented with worked examples that guide the reader through step‑by‑step calculations‚ reinforcing the connection between theory and practical application. See Appendix!!
Numerical Integration Techniques
Runge–Kutta methods‚ symplectic integrators‚ and adaptive step‑size control are explored. The text details algorithmic steps‚ stability analysis‚ and implementation tips for long‑term orbit propagation‚ emphasizing energy preservation and error bounds. Use these tools.?!
Runge-Kutta and Symplectic Integrators
Runge–Kutta (RK) schemes provide explicit‚ high‑order integration for ordinary differential equations governing orbital dynamics. The classic fourth‑order RK4 formula evaluates the state vector at four intermediate stages‚ yielding a local truncation error of O(h⁵) and a global error of O(h⁴). For smooth forces‚ RK4 balances accuracy and computational cost. Adaptive variants‚ such as RK45‚ adjust the step size using embedded error estimates‚ ensuring stability while conserving CPU cycles. Symplectic integrators preserve the Hamiltonian structure of conservative systems‚ conserving phase‑space volume and keeping energy error bounded over long periods‚ making them ideal for multi‑body gravitational simulations. The leapfrog (Störmer–Verlet) algorithm‚ a simple symplectic method‚ splits the Hamiltonian into kinetic and potential parts and alternates half‑steps. Higher‑order symplectic schemes‚ like the Yoshida 4th‑order integrator‚ combine multiple leapfrog stages with carefully chosen coefficients to achieve greater accuracy while retaining symplecticity. In practice‚ a hybrid approach couples a symplectic integrator for dominant gravitational forces with a high‑order RK method to handle non‑conservative perturbations such as atmospheric drag or solar radiation pressure. When implementing these integrators‚ careful step‑size selection is crucial‚ especially for highly eccentric orbits where velocity varies rapidly. Adaptive strategies mitigate phase errors without excessive computational load. Symplectic methods can also incorporate relativistic corrections by modifying the Hamiltonian to keep energy stable!!!! Students should experiment with both RK and symplectic schemes to understand trade‑offs between accuracy‚ stability‚ and computational effort.
Perturbation Theory
Perturbation theory extends two‑body models by adding small forces that alter trajectories. The 4th edition PDF teaches linearization‚ Lagrange planetary equations‚ and computing secular and periodic effects from atmospheric drag‚ solar radiation‚ and third‑body gravity for mission planning daily.
Atmospheric Drag‚ Solar Radiation‚ and Third-Body Effects
Atmospheric drag‚ significant in low Earth orbit‚ reduces altitude by acting opposite to velocity. Its acceleration depends on atmospheric density‚ velocity squared‚ and drag coefficient. Solar radiation pressure‚ caused by photon momentum‚ provides a continuous force that can change semi‑major axis and eccentricity‚ especially for high‑area‑to‑mass satellites. Third‑body perturbations from the Moon and Sun introduce periodic variations in orbital elements‚ leading to resonant effects such as lunisolar precession. Accurate modeling uses disturbing potentials and higher‑order terms‚ and numerical propagators integrate these forces over time.
In realistic mission design‚ the ideal two‑body model is perturbed by additional forces that gradually modify a spacecraft’s orbit. Atmospheric drag‚ though negligible beyond a few hundred kilometres‚ becomes dominant for low Earth orbits (LEO). The drag acceleration is proportional to the atmospheric density‚ the square of the relative velocity‚ and the drag coefficient‚ and it acts opposite to the velocity vector‚ causing a gradual decay of altitude and a precession of the orbital plane.
Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Lorem ipsum dolor sit amet‚ consectetur adipiscing elit. Sed ut perspiciatis‚ unde facereet
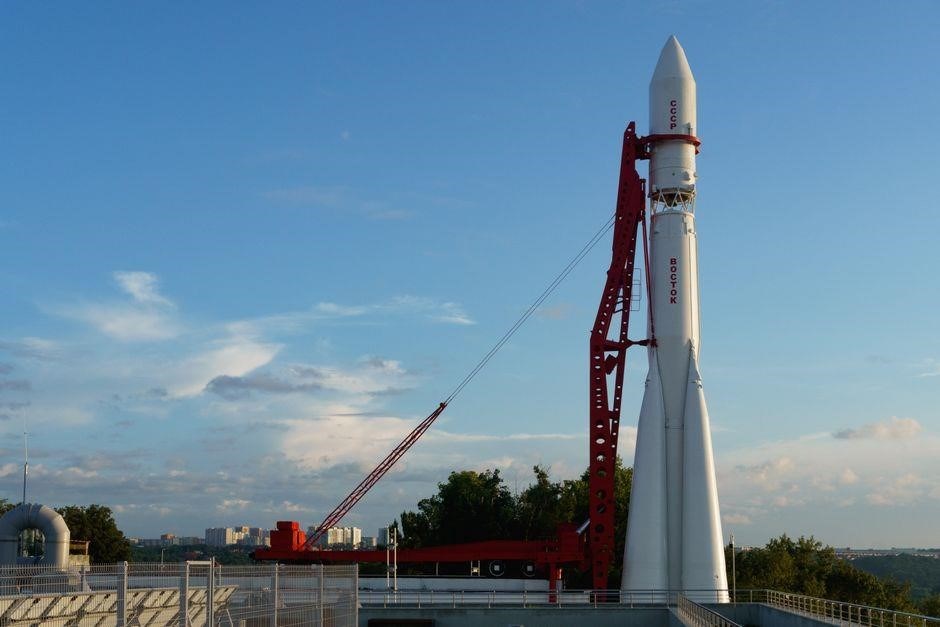
Spacecraft Guidance and Mission Design
Guidance systems compute optimal thrust profiles‚ using optimal control and trajectory optimization. Mission design integrates launch windows‚ transfer orbits‚ planetary alignment‚ ensuring fuel efficiency and constraints while meeting scientific objectives
Transfer Orbits‚ Launch Windows‚ and Interplanetary Trajectories
Designing interplanetary missions demands precise planning of transfer orbits‚ careful selection of launch windows‚ and mastery of trajectory dynamics. The 4th edition PDF presents a systematic approach that begins with the patched‑conic method‚ which approximates the spacecraft’s path as a sequence of two‑body segments. Students learn to calculate the required Δv for Hohmann transfers‚ bi‑elliptic maneuvers‚ and low‑energy trajectories such as the Oberth effect.
Launch windows are governed by synodic periods and planetary alignment. The text explains how to determine optimal launch dates using ephemeris data‚ and how to account for launch vehicle constraints‚ such as maximum thrust and gravity‑loss losses. It also covers the use of phase‑angle calculations to ensure rendezvous with target bodies.
- Hohmann transfer: efficient two‑impulse method for circular orbits.
- Bi‑elliptic transfer: advantageous for large semi‑major axis changes.
- Low‑energy transfer: exploits lunar or planetary gravity assists.
- Oberth maneuver: increases Δv by firing at periapsis.
- Gravity assists: use planetary flybys to alter velocity vector.
Trajectory optimization is addressed through numerical techniques such as the indirect method and direct collocation. The PDF illustrates how to formulate cost functions‚ impose constraints‚ and solve for optimal control laws. Sensitivity analysis and robustness checks are also discussed to handle uncertainties in thrust‚ mass‚ and planetary ephemerides.
By integrating these concepts‚ engineering students gain the ability to design missions that balance fuel economy‚ time of flight‚ and scientific return‚ preparing them for real‑world spaceflight challenges!!!
Supplementary Resources and Further Study
For students seeking deeper insight beyond the 4th edition PDF‚ a curated list of textbooks‚ software packages‚ and online platforms offers a comprehensive learning pathway. Classic references such as Vallado’s “Fundamentals of Astrodynamics and Applications‚” Wertz’s “Space Mission Analysis and Design‚” and Bate‚ Mueller‚ and White’s “Fundamentals of Astrodynamics” provide rigorous mathematical foundations and real‑world case studies. These works complement the PDF’s concise treatment of orbital mechanics by expanding on perturbation theory‚ attitude dynamics‚ and mission design optimization.
- Software: GMAT‚ STK‚ Orekit offer simulation tools. Use GMAT’s mission‑planning toolkit‚ STK’s interface‚ and Orekit’s API to model dynamics visualize ephemerides.
- Online Courses: MIT OpenCourseWare’s Space Dynamics Stanford Astrodynamics offer notes. Coursera’s Mission Design edX’s Orbital Mechanics labs assignments.
- Research Journals: AAS‚ Mechanics‚ Astronomy publish cutting‑edge studies andlow‑energy transfers nonlinear control.
- Community Forums: Exchange groups shareknowledg.
By engaging with these resources‚ students can reinforce theoretical concepts‚ gain hands‑on experience with simulation tools‚ and stay abreast of emerging trends in spaceflight engineering. Continuous learning through workshops‚ hackathons‚ and internships further bridges academic knowledge with industry practice.